High-Precision Laser SLAM Autonomous Forklifts & Transport Fleets
Explore our industrial-grade material handling robots engineered with reflector-free natural navigation, sub-centimeter docking precision, and embedded SCC multi-sensor dispatch controllers.
Global Landscape of AGV Navigation Methods: Architectural Evolution
From passive inductive physical tracks to environmental point-cloud simultaneous localization and mapping (SLAM), the industrial mobile robotics industry has undergone four fundamental technology transitions.
1. Magnetic & Optical Tape
Early automated guided vehicles relied exclusively on high-coercivity magnetic strips or color-contrast optical tapes embedded in the concrete floor. While providing extreme localization reliability (±2 mm), route modification requires intensive civil floor alterations, leading to high downtime and low facility flexibility.
2. QR Code / Grid Matrix
Commonly deployed in ecommerce goods-to-person (G2P) environments. Downward-facing industrial cameras decode high-density Matrix 2D barcodes glued to the floor. Absolute coordinate correction prevents dead-reckoning drift, but tape peeling, debris obstruction, and uneven surfaces create ongoing operational maintenance overhead.
3. Laser Reflector Triangulation
A revolving LiDAR head emits pulsed laser beams that bounce off retro-reflective markers positioned on structural columns and walls. Calculating angles against 3 or more calibrated targets achieves ±5 mm accuracy. It remains popular in heavy industrial manufacturing, but requires precise initial geometric survey and unobstructed sightlines.
4. Natural Laser SLAM (LiDAR)
The global gold standard championed by SCP Technology. High-frequency 2D/3D LiDAR scanners construct real-time point-cloud maps of surrounding industrial architecture without retroreflectors or magnetic modifications. Mathematical feature matching enables rapid 1-day deployment across dynamic production environments up to 400,000 m².
5. Visual SLAM (vSLAM)
Stereoscopic and monocular depth cameras process structural image features (ORB, SIFT) coupled with visual inertial odometry (VIO). Exceptional for rich 3D perception and spatial semantic parsing. However, factory lighting fluctuations, direct sunlight, and dust environments necessitate multi-sensor sensor fusion with primary LiDAR channels.
6. Hybrid Fusion Navigation
Combining Laser SLAM for large-area contour positioning with auxiliary ceiling QR code grids or floor magnetic spots at precision picking/docking stations. Hybrid architectures guarantee unbroken continuous navigation even when dynamic cargo fluctuations alter more than 75% of surrounding environmental laser point clouds.
| Navigation Method | Positioning Precision | Floor / Structural Modification | Deployment Commissioning Period | Dynamic Environment Resilience | Ideal Application Profile |
|---|---|---|---|---|---|
| Natural Laser SLAM (SCP Standard) | ±5 mm to ±10 mm | Zero Modification | 1 to 3 Days | High (Up to 70% dynamic changes) | High-mix low-volume lines, lights-out warehouses |
| Laser Reflector Triangulation | ±3 mm to ±5 mm | Reflector target calibration on pillars | 2 to 4 Weeks | High (Requires direct sightline to reflectors) | Fixed wide-aisle distribution centers |
| QR Code / 2D DataMatrix Grid | ±5 mm to ±10 mm | Dense floor barcode installation | 1 to 2 Weeks | Moderate (Debris / surface scratch risk) | Ecommerce sorting hubs, KIVA-style AMR grids |
| Magnetic Tape / Marker | ±2 mm to ±5 mm | Floor slotting or surface adhesives | 2 to 3 Weeks | Low (Route modification requires physical work) | Static automotive assembly lines |
| Multi-Sensor Hybrid Fusion | ±2 mm to ±5 mm | Minimal auxiliary markers at end-points | 3 to 7 Days | Ultra-High (Sensor redundancy fallback) | Dense multi-tier high-bay racking, cold storage |
The Mechanics of Industrial Laser SLAM: Mathematical Certainty
Natural Feature Laser SLAM transforms raw point-cloud data into deterministic navigation trajectories without human intervention. At SCP Technology, our mobile robots integrate the proprietary SCC Controller running optimized Graph-SLAM and Extended Kalman Filter (EKF) algorithms.
By synchronizing high-speed wheel odometry, solid-state 6-axis IMU angular velocities, and 360-degree LiDAR returns at 50Hz, the navigation engine creates a probability density map where positional drift is continuously corrected via scan matching against static structural landmarks.
- Sub-Centimeter Docking: Patented algorithm modules deliver ±5 mm precision docking directly into pallet fork pockets without guide rails.
- Ultra-Large Scale Point Clouds: Single-map coverage handles facility expanses exceeding 400,000 m² with real-time multi-layer partitioning.
- Dynamic Obstacle Filtering: Moving workers, cross-traffic forklifts, and staging pallet clusters are filtered out of the static base map dynamically.
SCP SCC Industrial Robotic Core
The central intelligence unit driving real-time kinematics, functional safety zones, and enterprise fleet handshakes.
Engineering White Paper Takeaway: In real-world enterprise deployments, 90% of autonomous forklift downtime stems from poor navigation adaptability in changing environments. By utilizing Natural Laser SLAM driven by the SCC Controller, facilities eliminate infrastructure maintenance while achieving continuous localization repeatability under extreme operational variance.
Why China AGV Manufacturers Lead Global Market Efficiency
China has emerged as the global epicenter for industrial robotics engineering, driven by concentrated supply-chain clusters, complete upstream-to-downstream vertical integration, and rapid prototyping cycles.
1. Comprehensive Supply Chain Clustering
Within key Chinese manufacturing zones (such as Sichuan, the Yangtze River Delta, and Guangdong), over 92% of AGV components—from automotive-grade stamped steel chassis, precision planetary reducers, and high-density LiFePO4 battery packs to 3D time-of-flight LiDAR—are sourced within a 150-kilometer radius. This hyper-localized ecosystem eliminates transatlantic lead-time bottlenecks.
2. Rapid Prototyping & 1-Day Commissioning
While European and North American AGV integrators frequently quote 12 to 24 weeks for mechanical engineering adaptations and on-site reflector installation, Chinese OEM suppliers like SCP Technology leverage pre-integrated Laser SLAM kinematics and modular controller hardware, allowing zero-retrofit sites to complete active fleet commissioning in as little as 24 to 72 hours.
3. Unmatched CapEx-to-Performance Ratio
Vertical supply chain integration delivers an average 40% to 55% reduction in total capital expenditure (CapEx) without compromising component tier standards. Standard inclusions such as dual safety LiDARs, 3D obstacle avoidance cameras, regenerative braking, and industrial touch terminals deliver sub-18-month payback timelines for multinational manufacturing operations.
Localized Application Scenarios: Field-Tested Automation Profiles
Real-world deployment demands engineering precision tailored to strict environmental constraints. Explore how SCP smart forklifts and AMR chassis execute non-stop operations across diverse industrial settings.
Automotive & Powertrain Assembly
Challenge: Just-in-Sequence (JIS) feeding of heavy engine blocks and transmission cases requires tight cycle synchronicity across narrow line-side corridors.
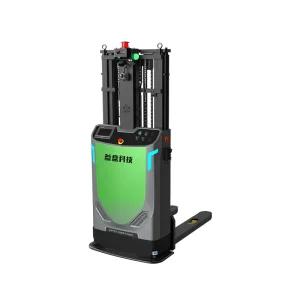
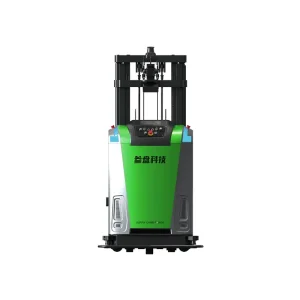
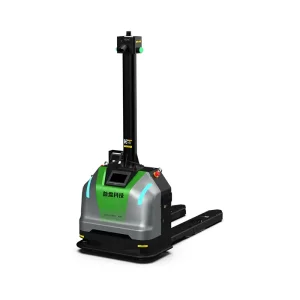
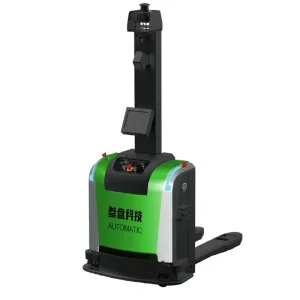
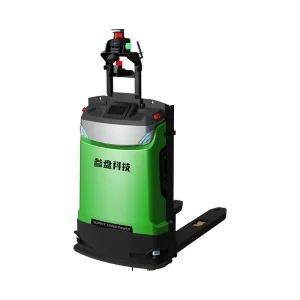
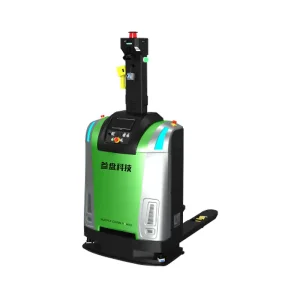
Solution: Compact SFL-CBD15-ZL handling forklifts and AMB-CSW10-BH top-lifting AMRs coordinate via MES APIs to deliver sub-second dispatch to workstations, eliminating manual tugger congestion and human forklift traffic hazards.
Cold Chain Logistics & Deep Freeze
Challenge: Operating temperatures dipping to -25°C cause rapid battery capacity decay, optical sensor lens fogging, and moisture condensation during ambient staging.
Solution: Specialized cold-temperature sealed chassis equipped with thermostatic internal heating circuits for LiDAR transceivers, IP54 electrical protection, and high-rate LiFePO4 batteries ensuring unbroken pallet transport between freezers and temperature-controlled docks.
FMCG & Retail Distribution Centers
Challenge: Dynamic staging areas where high pallet turnover alters the physical layout constantly, disorienting standard SLAM maps.
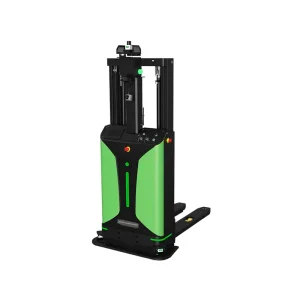
Solution: High-mast SFL-CDD16 stackers and SCP101 Floor Sorting Scales integrated with Server X Store fleet controllers. AI-driven 3D cameras automatically recognize pallet fork pockets, even if misaligned up to ±10 degrees or placed at varying elevation levels.
Semiconductor & Cleanroom Electronics
Challenge: Strict cleanroom cleanliness classes (ISO Class 6), electrostatic discharge (ESD) mitigation, and zero particulate generation during motion.
Solution: Anti-static polyurethane drive wheels, enclosed hydraulic lifters without open grease reservoirs, and sub-millimeter smooth deceleration curves that eliminate cargo tipping risks during wafer and circuit board transport.
Global Enterprise Procurement Matrix: Evaluating Chinese Suppliers
Sourcing AGV and autonomous forklift systems requires a strict procurement framework that examines safety certifications, protocol interoperability, total cost of ownership (TCO), and local commissioning support.
Critical Technical Vetting Points for Overseas Buyers
When evaluating proposals from China AGV manufacturers, procurement directors must look past headline equipment purchase prices and verify four non-negotiable engineering layers:
- Safety Architecture Level: Verify that obstacle detection circuits rely on certified Type 3 / Type 4 safety laser scanners wired directly into safety relays or fail-safe PLCs (EN ISO 13849-1 Cat 3 / PL d), avoiding simple commercial-grade sensors.
- Fleet Protocol Interoperability: Require compliance with the European VDA 5050 standard. This guarantees your enterprise can orchestrate SCP robots alongside legacy equipment under a unified third-party dispatch master.
- WMS / ERP REST API Completeness: Ensure native bidirectional connectors exist for SAP, Oracle SCM, Manhattan Associates, or proprietary MES systems to avoid custom middleware development costs.
Lifecycle TCO Calculation Model (3-Year Horizon)
Emerging Technologies Shaping Autonomous Guided Vehicles
The next decade of intralogistics robotics is defined by artificial intelligence, cloud-native dispatch, and cognitive sensor convergence.
AI 3D Deep Learning & Pallet Pose Estimation
Traditional autonomous forklifts expect pristine pallets positioned at fixed coordinates. Next-generation systems feature deep-learning convolutional neural networks (CNNs) capable of identifying cracked wood pallets, irregular shrink-wrapping, and distorted skids in real time, auto-adjusting fork tip angles on the fly.
Deterministic 5G-Advanced & Cloud Fleet Slicing
Replacing traditional Wi-Fi roaming—which is notorious for signal dropouts when vehicles traverse tall steel rack canyons—5G Private Networks deliver sub-10ms deterministic latency, enabling heavy SLAM point-cloud rendering tasks to offload to edge industrial computers without onboard thermal throttling.
Lights-Out Warehouse Orchestration Towers
Autonomous mobile handling is converging with automated storage and retrieval systems (ASRS), automated parcel sortation scales, and high-speed robotic depalletizing arms under cloud-native Control Tower software, creating unified zero-human distribution networks.
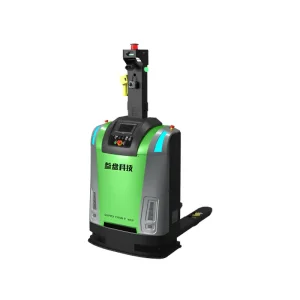
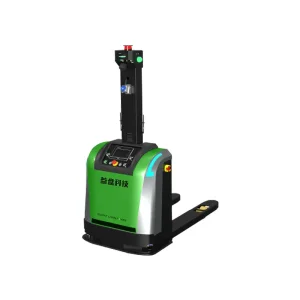
Enterprise Autonomous Fleet Range: Stacking, Handling & AMR Chassis
Review additional field-proven industrial AGV models manufactured to strict international CE machinery safety and material handling standards.


Enterprise AGV Navigation: Frequently Asked Engineering Questions
In-depth responses compiled by SCP Technology's senior autonomous mobile robotics engineering division to support your procurement vetting.
How does Natural Feature Laser SLAM handle environments where static features change frequently?
Natural Feature Laser SLAM matches real-time LiDAR point clouds against a persistent global reference map. In high-turnover logistics centers where pallet stacks move constantly, our SCC Industrial Controller divides the point cloud into static structural layers (pillars, permanent structural walls, fixed overhead mezzanines) and dynamic transitory layers (staging cargo, personnel, transient vehicles).
The system requires as little as 30% to 35% static geometric consistency to maintain unbroken localization accuracy at ±5 mm. If environment alterations exceed 70%, the software supports multi-sensor fusion fallbacks, incorporating high-precision wheel odometry and 3D visual inertial sensors to bridge unrecognized zones without emergency stops.
What is the realistic timeline for deploying a fleet of autonomous forklifts in a functioning facility?
For facilities deploying SCP Laser SLAM smart forklifts on standard compatible concrete floors, zero structural retrofits are required. Our engineers walk the vehicle through the warehouse via hand-held teach-pendant or manual drive to capture environmental LiDAR point clouds. A 50,000 m² facility map is typically generated and zoned within 4 to 8 hours.
Following map compilation, virtual traffic lanes, speed limits, pallet pickup docking poses, and charging stations are defined digitally. In standard configurations, single-vehicle commissioning takes 1 day, while multi-vehicle fleet integration (including Server X Store dispatching and WMS API test handshakes) is typically completed within 5 to 7 operational days.
How do SCP autonomous vehicles interface with existing enterprise WMS, MES, and ERP systems?
SCP mobile robots utilize an open API architecture adhering to international VDA 5050 communication standards. The Server X Store fleet orchestration engine provides lightweight RESTful endpoints, WebSockets, and MQTT message brokers that connect directly into tier-1 enterprise platforms including SAP EWM, Oracle SCM, Manhattan Associates, and customized proprietary MES setups.
Mission triggers (e.g., inbound pallet scanned at receiving dock) create instant JSON task payloads transmitting target pick coordinates, carrier type, priority level, and destination buffer racks. The fleet manager automatically allocates tasks to the optimal robot based on state-of-charge (SoC) and traffic proximity.
What functional safety standards and certifications do Chinese AGVs meet for North American and European imports?
Industrial machinery exported to European and North American markets must satisfy stringent machinery directives. SCP smart forklifts comply fully with EN ISO 3691-4:2023 (Safety requirements for driverless industrial trucks and their systems) and ANSI/ITSDF B56.5.
Our sensor architecture integrates certified safety LiDAR scanners wired into fail-safe PLC modules delivering Performance Level d / Category 3 (PL d / Cat 3) compliance under EN ISO 13849-1. Dynamic safety fields automatically expand or retract based on current travel speed, steering angle, and payload mass, preventing contact with personnel and physical equipment.
What are the differences between 2D LiDAR SLAM, 3D LiDAR SLAM, and Visual SLAM in industrial use?
2D LiDAR SLAM: Scans along a single horizontal plane (typically 200–300 mm above the floor). Highly mature, computationally efficient, and perfect for structured warehouses with permanent walls and uniform vertical columns.
3D LiDAR SLAM: Emits multi-channel laser arrays (16 to 128 beams) creating a dense 3D spatial voxel map. Superior for outdoor transitions, uneven flooring, ramps, and non-standard warehouse spaces with high volumetric variability.
Visual SLAM (vSLAM): Utilizes optical stereo camera pairs to track visual feature points. Excellent for recognizing specific pallet types, barcode markers, and high-altitude features, but susceptible to changing lighting conditions and ambient dust. SCP primarily pairs 2D/3D LiDAR SLAM with 3D vision cameras in a hybrid sensor fusion topology.
How does the battery swap and fast-charging system work to maintain 24/7 continuous operations?
SCP smart forklifts are engineered for round-the-clock operations without downtime bottlenecks. Vehicles feature dual lithium iron phosphate (LiFePO4) battery packs supporting high-rate opportunity charging. While docked for automated pallet loading or between dispatched missions, side-mounted floor charging plates recharge the pack at up to 1C (achieving 80% charge within 45 to 60 minutes).
For peak, continuous logistics surges, vehicles feature an ergonomic manual or automated battery swap drawer allowing operators to exchange power units in less than 2 minutes, returning the AGV to full service immediately.